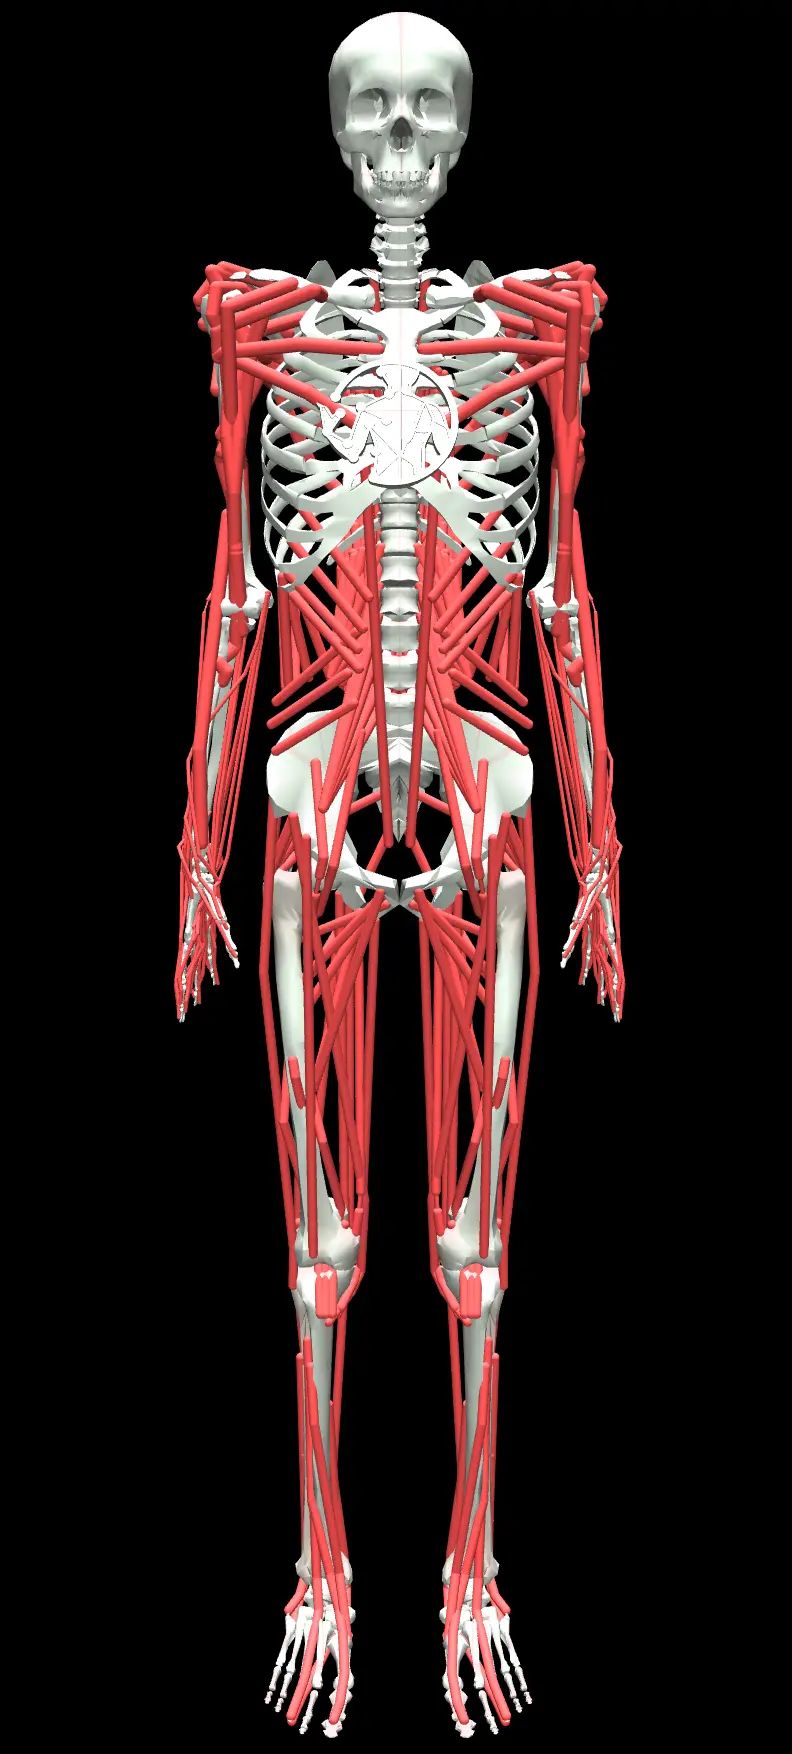
MuJoCo + Gymnasium
CPU environments such as myoElbowPose1D6MRandom-v0 with physiological musculotendon actuators.
MyoSuite
Physiologically grounded muscles, MuJoCo physics, and RL-ready tasks — open for labs building the next generation of motor intelligence.
University contributors
Imperial College
King's College
University of Cambridge
Northeastern University
McGill University
EPFL
University of Toronto
Overview
MyoSuite is a collection of environments and tasks solved by musculoskeletal models to understand human dexterity and agility.


MyoSim library
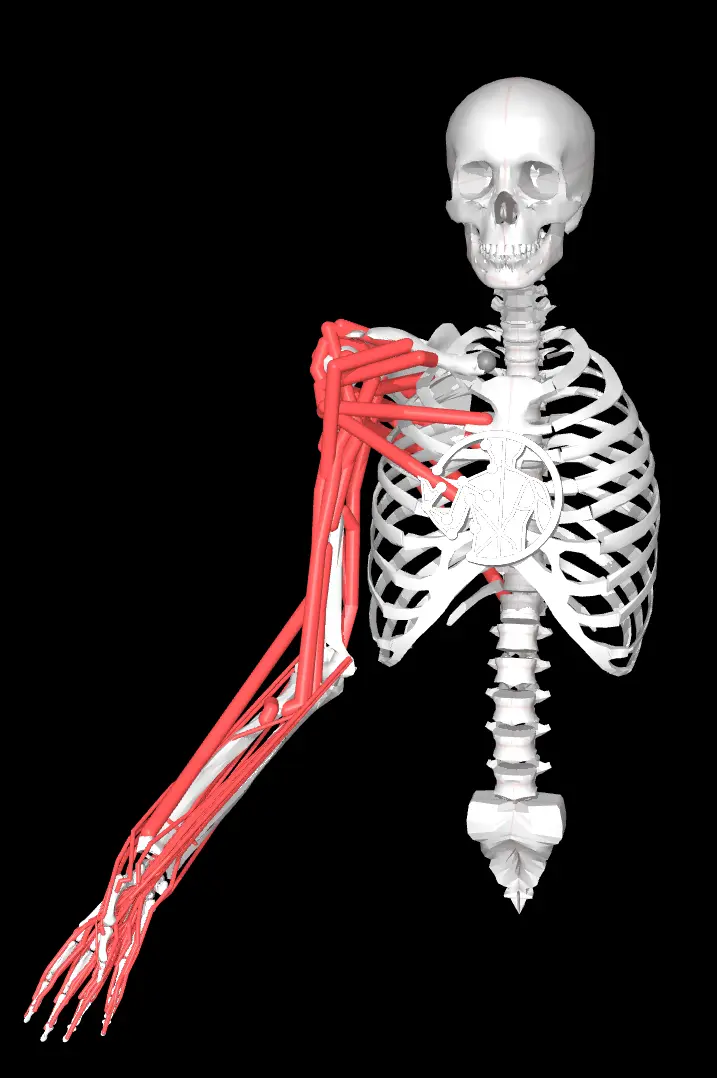
Stable body models from MyoSim — elbow and finger legacy models on the full catalog.
Multi-platform · Linux, macOS, Windows, and Colab — install with pip, conda, or uv.
CPU environments such as myoElbowPose1D6MRandom-v0 with physiological musculotendon actuators.
JAX/MJX and Warp/Isaac (mjlab) ports for elbow, finger, hand, gait, and mimic families.
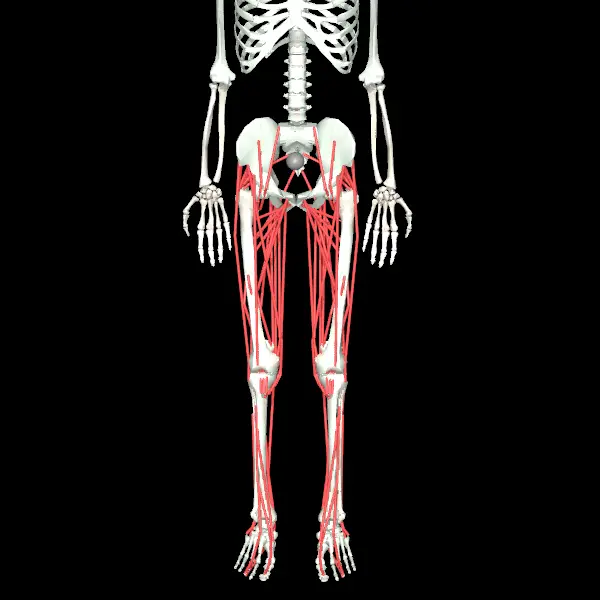
Anatomically detailed XML fragments and composed assemblies from MyoHub/myo_sim.
Audience guides for biomechanics, neuroscience, ML, and rehab plus notebook tutorials.
Conference on Robot Learning (CoRL) · 2022
Vittorio Caggiano, Huawei Wang, Guillaume Durandau, Massimo Sartori, Vikash Kumar
arXiv · 2026
Chengkun Li, Cheryl Wang, Bianca Ziliotto, Merkourios Simos, Jozsef Kovecses, Guillaume Durandau, Alexander Mathis
MyoHub/myosuite · ongoing
MyoSuite maintainers
From researchers using MyoSuite in their own work.
“MyoSuite has been pretty painless to work with so far, nice work ... my policies seem to converge nicely as well on my first attempt.”
“Working with MyoSuite is great, it makes it so much simpler to train agents to control musculoskeletal systems.”
CoRL 2022 · arXiv:2205.13600
@Misc{MyoSuite2022,
  author = {Caggiano, Vittorio AND Wang, Huawei AND Durandau, Guillaume AND Sartori, Massimo AND Kumar, Vikash},
  title = {MyoSuite -- A contact-rich simulation suite for musculoskeletal motor control},
  publisher = {Learning for Dynamics and Control (L4DC)},
  year = {2022},
  howpublished = {\url{https://github.com/MyoHub/myosuite}},
  doi = {10.48550/ARXIV.2205.13600},
  url = {https://arxiv.org/abs/2205.13600},
}Join the competition, the workshop series, and the demo archive.